Rover Fin-Ray End Effector
A compliant gripper — mostly for the driver’s sake.
| Where | UCSD Yonder Dynamics |
|---|---|
| When | 2026 |
| Materials | TPU fingers, FDM-printed ASA housing, heat-set inserts, rubber-laminated contact faces |
| Outcome | Fielded on our 2026 University Rover Competition rover |
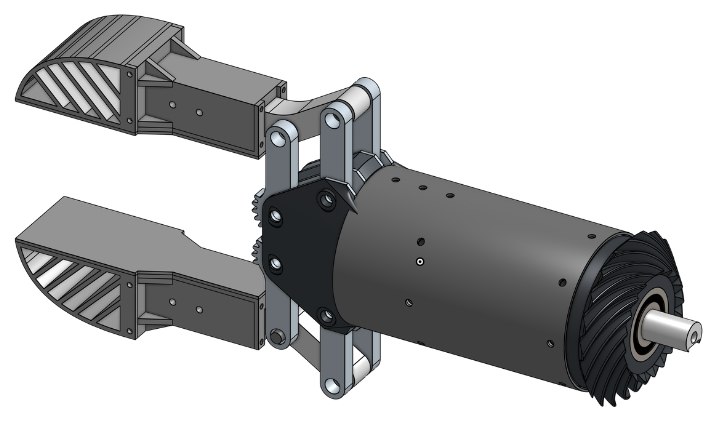
Our rover’s manipulator has to pick up a wide variety of objects, often things we can't fully specify in advance given our competition's annual rule changes. We'd been using a rigid gripper and running into problems with cylindrical objects slipping, resulting in a generally poor experience for the driver.
I designed a fin-ray gripper printed in TPU. The compliant ribs act like columns and buckle in a controlled manner, which lets each finger conform around whatever it contacts. The main chassis is printed ASA with heat-set inserts for the TPU overlay, and I laminated the contact surface with rubber for slightly better traction — the printed TPU was quite greasy on its own.
It went to competition on the rover and worked well for the missions we were able to compete in. It picked up our cylindrical microscope for the science mission, for example, which used to be much harder with a rigid plastic end effector.